If you’ve ever stood on a factory floor watching a robotic arm lift a 50kg payload with the kind of precision a human can’t match, or seen a collaborative robot gently place a fragile circuit board without warping it, you’ve witnessed robot joint load-carrying capacity at work. For my team—we’ve supplied high-performance robot joints to manufacturers for over a decade—this isn’t just a technical specification; it’s the foundation of every joint we build and every client project we support. Too many engineers and integrators overlook how tightly load-carrying capacity ties to every part of joint selection, from motor sizing to gear type to application longevity, and that’s a mistake that leads to everything from shortened robot lifespans to costly downtime. Robot Joint

Let’s start with the basics: load-carrying capacity in a robot joint isn’t a single number. It’s a combination of two critical metrics: peak load (the maximum weight a joint can handle for short, intermittent bursts, like lifting a heavy box from a conveyor to a pallet) and continuous load (the steady weight a joint can support indefinitely, like holding a camera arm focused on a moving assembly line for hours). For example, a palletizing robot loading heavy freight will rely on peak load, while a surgical robot assisting with delicate tissue manipulation depends entirely on continuous load consistency. Many first-time buyers only look at peak load, assuming that’s the hard limit, but that’s rarely where things go wrong. Last year, we worked with an automotive parts integrator who ordered joints rated for 150kg peak load for their wheel assembly line, ignoring that the joint would hold a 120kg payload for 8 hours straight. Their initial setup failed after three months, because continuous load capacity was only 90kg—too close to their steady operating weight, leading to excessive gear wear and overheating. That’s a common misstep, and it’s why we walk every new client through both metrics before we even discuss pricing.
Now, how does this translate into actual joint selection, beyond just checking boxes on a spec sheet? Let’s break this down by joint type, since load-carrying capacity is what dictates which design is right for which job. The two most common joints we supply are rotary joints (used for the shoulder, elbow, and wrist of articulated robots) and linear joints (used for extending or retracting a robot’s reach, like a telescoping arm on a warehouse robot). For rotary joints, load-carrying capacity ties directly to the gear ratio and output torque. A joint with a high gear ratio can handle heavier loads, but only if the motor has enough power to move that load without stalling. We saw this firsthand with a metal stamping client who needed a 200kg payload joint for a spot-welding robot. They initially opted for a high-ratio harmonic drive joint, which is lightweight and precise for small, high-speed tasks, but harmonic drives peak at around 150kg peak load—too low for their needs. We switched them to a planetary gear joint, which can handle up to 350kg peak load with the same motor size, because planetary gears distribute load across multiple gear teeth instead of a single spline, reducing wear even under heavy use. The result? Their robot now runs 24/7 without the gear slippage they experienced with the harmonic drive, and their maintenance costs dropped by 40% in six months.
For linear joints, load-carrying capacity is even more nuanced, because it’s not just about lifting weight—it’s about side load, too. Side load is the force applied perpendicular to the joint’s axis, like when a robot arm extends far out and the wrist joint pulls sideways from the weight of a tool. A lot of integrators forget this, especially when working with gantry robots or long-reach arms. Last quarter, a packaging company reached out because their linear joints were failing every two months. They were using a standard ball screw linear joint rated for 100kg axial load, but they were mounting a 75kg robot head 1 meter beyond the joint’s recommended extension, creating 25kg of side load. We replaced their ball screw joints with roller screw linear joints, which have a much higher side load rating—up to 3x that of ball screws. Now those joints have gone 10 months without failure, and their production line has had zero unplanned shutdowns related to joint issues. This is a key point: load-carrying capacity isn’t just about the payload number on your design drawing. It’s about how that payload is distributed across the joint, whether it’s axial, radial, or side load, and how the joint’s internal components are built to handle those forces.
Another factor tied directly to load-carrying capacity is duty cycle. Duty cycle is the percentage of time a joint is operating at peak load over a set period (usually a minute). For applications with a 100% duty cycle—like a material handling robot moving 24 hours a day—continuous load capacity is non-negotiable. Joints with high peak load ratings often have lower continuous load limits, because their design prioritizes short bursts over steady stress. For example, a joint used in a pick-and-place robot that moves parts every 5 seconds (low duty cycle) can handle a payload 20% higher than its continuous load rating, but a joint used in a CNC machine that holds a cutting tool in place for hours at a time can only handle 10% over its continuous load. We always map a client’s duty cycle to our joint load specs during the consultation, because mismatched duty cycle and load capacity leads to thermal expansion. When a joint runs under steady heavy load, its internal parts heat up, expand, and can cause misalignment, which ruins precision. We had a consumer electronics client last year that switched our joints out for cheaper, off-brand ones for their circuit board assembly line. Those off-brand joints had a 10kg peak load rating and a 7kg continuous rating, but the client was running them at 95% of continuous load for 12 hours a day. The joints overheated by 15 degrees Celsius, causing the motor windings to degrade, and they had to replace all 12 joints after 4 months. Our joints, by contrast, have a 12kg continuous load rating for that same size motor, so they run at 58% of continuous load at their operating weight, staying well within their thermal limit. That’s the difference between building load capacity into the design and cutting corners on the spec.
Then there’s the robot’s overall weight and kinematic chain, which is a part of joint load-carrying capacity that’s often overlooked. Each joint in a series (shoulder, elbow, wrist) carries not just the payload, but the weight of all the joints and links above it. So a wrist joint handling a 5kg payload has an elbow joint 10kg above it plus the wrist itself, meaning the elbow joint’s load rating has to account for both the wrist weight and the payload, not just the payload. Last year, a university robotics lab designed a small research robot and ordered our wrist joints rated for 5kg, but they didn’t account for the elbow joint’s 8kg mass. The wrist joint was having trouble maintaining position when the robot moved, because it was actually carrying 13kg total (5kg payload + 8kg wrist weight). We adjusted their selection to a wrist joint rated for 15kg peak load, which was still lightweight enough for their small robot but had the extra capacity to handle the combined weight. This is why we don’t just give clients a spec sheet and send them on their way—we ask for the full kinematic layout, not just the payload number. A client who tells us they need a joint for 20kg might actually need a 30kg rated joint if they’re not accounting for the mass of the links above.
Now, let’s talk about edge cases that force load-carrying capacity to become even more critical. Collaborative robots (cobots), which are designed to work alongside humans, have to balance load capacity with safety. Cobots can’t have joints that exert too much force if they bump into a worker, so their load-carrying capacity is lower than industrial robots of the same size. But even within cobots, load specs matter. A cobot used for palletizing (lower payload, higher repetition) will have a different load requirement than one used for assembly work requiring fine movement, because the assembly cobot needs consistent torque for precision, not just peak lift. We’ve engineered custom joints for cobot manufacturers that have built-in torque sensors, so if the joint hits a human, it can reduce its load capacity on the fly without sacrificing the ability to handle its rated payload when working on a task. That’s a perfect example of how load-carrying capacity isn’t just about strength—it’s about matching the joint’s load handling to the application’s needs, whether that’s speed, precision, or safety.
Another edge case is harsh environments. Robots working in cold storage, foundries, or outdoor construction sites have to handle extreme temperatures, dust, moisture, and vibration, all of which reduce a joint’s effective load-carrying capacity. Lubricants thicken in cold, reducing gear efficiency, while high heat breaks down lubricants, increasing wear. Vibration can cause joint components to loosen, leading to uneven load distribution. For a food processing client working in a wet, high-salt environment, we supplied stainless steel joints rated for 100kg peak load, but we added sealed bearings to prevent corrosion. Those sealed bearings reduced the effective load rating by 10%, but in that environment, a non-sealed joint would have degraded enough to only handle 50kg within a year, so the tradeoff was worth it. We always adjust load specs for environmental factors during customizations, because a joint rated for 200kg in a clean room might only be good for 180kg in a dusty factory floor.
At the end of the day, selecting a robot joint isn’t a one-size-fits-all process, and load-carrying capacity is the thread that ties every decision together. It’s not just about picking the highest number to avoid problems—it’s about matching peak vs. continuous load, accounting for side load and duty cycle, calculating the mass of the entire kinematic chain, and adjusting for environmental conditions. We’ve seen too many integrators and engineers learn this the hard way, with costly downtime, premature joint replacement, or underperforming robots. That’s why we take the time to walk through every step with every client: we ask about their payload, their duty cycle, their application environment, the weight of their robot links, and even their maintenance budget. We don’t just sell joints—we help our clients pick the right load capacity for their specific job, so their robots run smoothly for years.
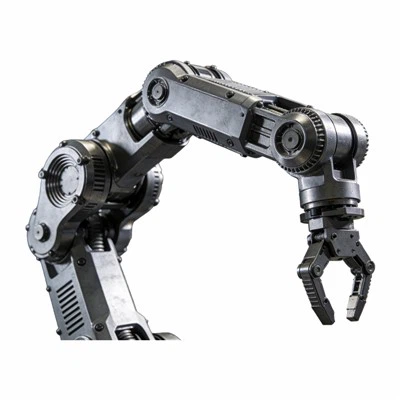
If you’re designing a new robotic system, upgrading an existing line, or dealing with unexpected joint failures that are eating into your productivity, we can help. We’ve supplied joints to thousands of clients across every industry, from automotive manufacturing to medical devices to warehouse automation, and we have the engineering expertise to match your load requirements to the perfect joint. Whether you need a standard off-the-shelf joint or a custom-designed one for a unique application, our team is ready to discuss your project and provide the support you need to make the right choice for your operations. Don’t let load-carrying capacity be an afterthought—let’s connect today to find the right joint solution for your needs.
Sheet Metal References
- Craig, J. J. (2005). Introduction to Robotics: Mechanics and Control (3rd ed.). Pearson Education.
- Robotics Industries Association. (2022). Robotic Joint Component Performance Standards. RIA Publication R15.06.
- Zhou, J., & Liu, H. (2020). Load-Carrying Capacity Analysis of Planetary Gear Drives for Industrial Robot Joints. Journal of Mechanical Design, 142(8), 082301.
- International Organization for Standardization. (2018). ISO 10218-1: Robots and robotic devices – Safety requirements for industrial robots – Part 1: Robots. ISO.
- Smith, A. B., & Carter, D. E. (2021). Thermal Effects on Robot Joint Load Capacity in Extreme Operating Environments. Journal of Robotics and Mechatronics, 33(4), 789-798.
Shenzhen Jingcheng Dingyi Forming Technology Co., Ltd.
Address: 1st Floor, Building 3, Huafeng Zhenbao Industrial Park, No.137 Shihuan Road, ShiYan Town, Bao’An District, ShenZhen, PRC
E-mail: 13071475061@163.com
WebSite: https://www.jctop-cnc.com/
